WLKATA March X Pro LiDAR Kit
BDT 3,299,400/-
Product Details
Brand: WLKATA
Model: WL-MarchX-Pro-LiDAR-NX35R
Country Of Origin: USA
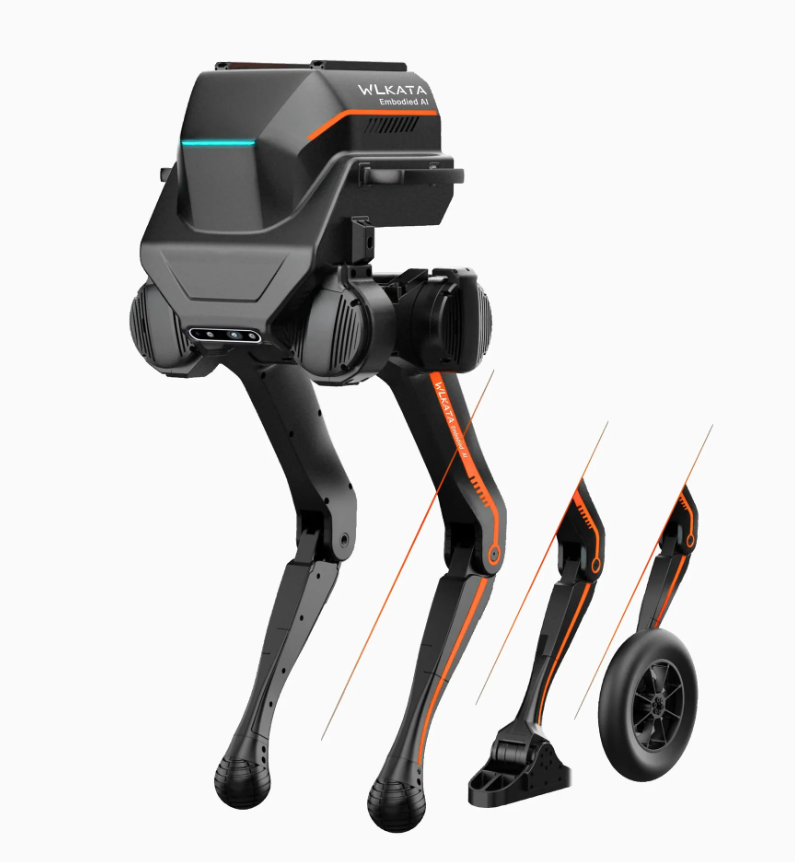
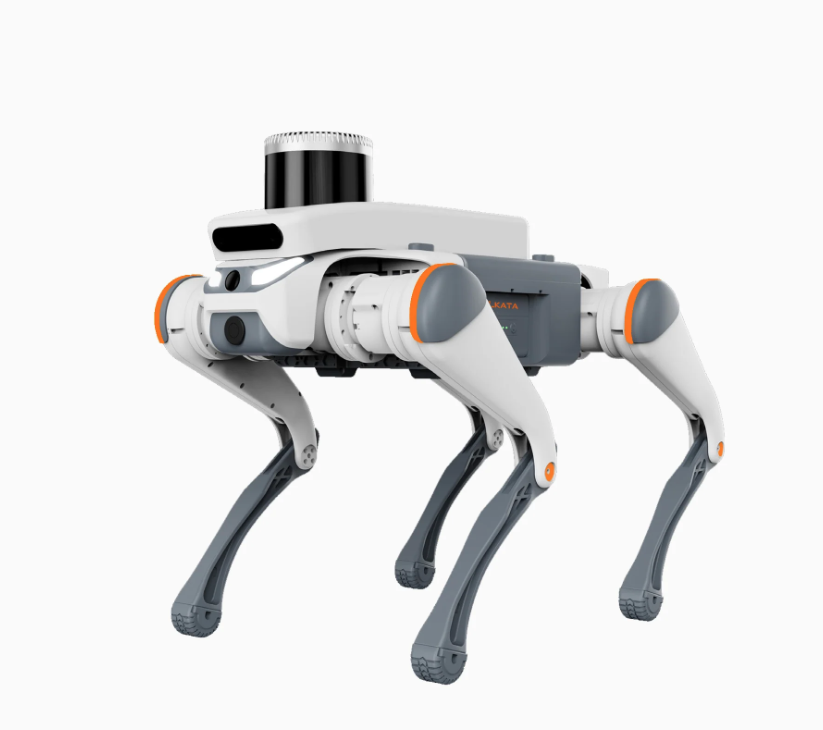
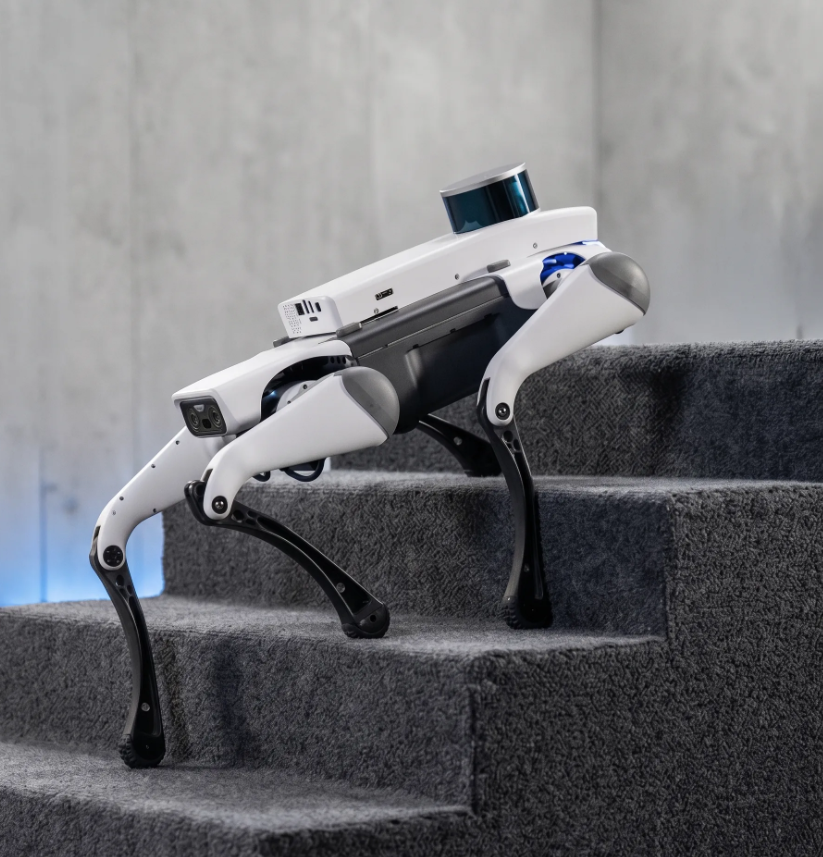
A quadruped robotics platform equipped with LiDAR and multi‑sensor perception for autonomous navigation and mapping. Features include multi‑line 3D LiDAR mapping, SLAM navigation, RGB‑D cameras, and an open SDK with ROS1/ROS2 full API support. Designed for robotics research, autonomy development, and real‑world deployment.
Key Specifications
Physical
Specification Details
Weight (with Battery) 13.7 kg / 30.2 lb
Dimensions (Standing) 24 × 14.5 × 15.7 in (610 × 370 × 406 mm)
Performance
Specification Details
No-Load Duration 1.5–2 hours
Range 5 km
Load Capacity (Continuous Walking) 7.5 kg
Sensing & Control
Specification Details
Wide-Angle Camera 130° horizontal FOV, 1920 × 1080 @ 30 fps
Ultrasonic Radar 2 sets (built-in)
Front Light Built-in
Remote Control Included
Auto-Stop / People Tracking Front & rear
Obstacle Avoidance Yes
Compute & Platform
Specification Details
Interface Extension Module Pre-installed on top of the robot's back
Depth Camera Intel RealSense D435i
Onboard Computing NVIDIA Jetson Xavier NX (Ubuntu) with built-in ROS
LiDAR 16 lines; detection distance: 100 m @ 10%, 150 m @ 70%
Development Support Simulation model, SDK, API, demo, perception interface, and documentation
| Equipped with: | A quadruped robotics platform equipped with LiDAR and multi‑sensor perception for autonomous navigation and mapping. |
| Features include: | Features include multi‑line 3D LiDAR mapping, SLAM navigation, RGB‑D cameras, and an open SDK with ROS1/ROS2 full API support. |
| Designed for : | Designed for robotics research, autonomy development, and real‑world deployment. |
A quadruped robotics platform equipped with LiDAR and multi‑sensor perception for autonomous navigation and mapping. Features include multi‑line 3D LiDAR mapping, SLAM navigation, RGB‑D cameras, and an open SDK with ROS1/ROS2 full API support. Designed for robotics research, autonomy development, and real‑world deployment.
Key Specifications
Physical
Specification Details
Weight (with Battery) 13.7 kg / 30.2 lb
Dimensions (Standing) 24 × 14.5 × 15.7 in (610 × 370 × 406 mm)
Performance
Specification Details
No-Load Duration 1.5–2 hours
Range 5 km
Load Capacity (Continuous Walking) 7.5 kg
Sensing & Control
Specification Details
Wide-Angle Camera 130° horizontal FOV, 1920 × 1080 @ 30 fps
Ultrasonic Radar 2 sets (built-in)
Front Light Built-in
Remote Control Included
Auto-Stop / People Tracking Front & rear
Obstacle Avoidance Yes
Compute & Platform
Specification Details
Interface Extension Module Pre-installed on top of the robot's back
Depth Camera Intel RealSense D435i
Onboard Computing NVIDIA Jetson Xavier NX (Ubuntu) with built-in ROS
LiDAR 16 lines; detection distance: 100 m @ 10%, 150 m @ 70%
Development Support Simulation model, SDK, API, demo, perception interface, and documentation
The WLKATA March X Pro LiDAR Kit is a high‑end quadruped robotics solution built for autonomy, mapping, and intelligent mobility. With integrated LiDAR, RGB‑D cameras, and SLAM navigation, it delivers advanced multi‑sensor perception for real‑world robotics research. The open SDK with ROS1/ROS2 support makes it ideal for developers, universities, and labs working on autonomous navigation and AI robotics. Backed by secure payment options and ready‑to‑use deployment, it’s a powerful tool for cutting‑edge robotics innovation.
Asked by Visitor
100% Viscose Fabric.
Thank You.
Asked by Visitor